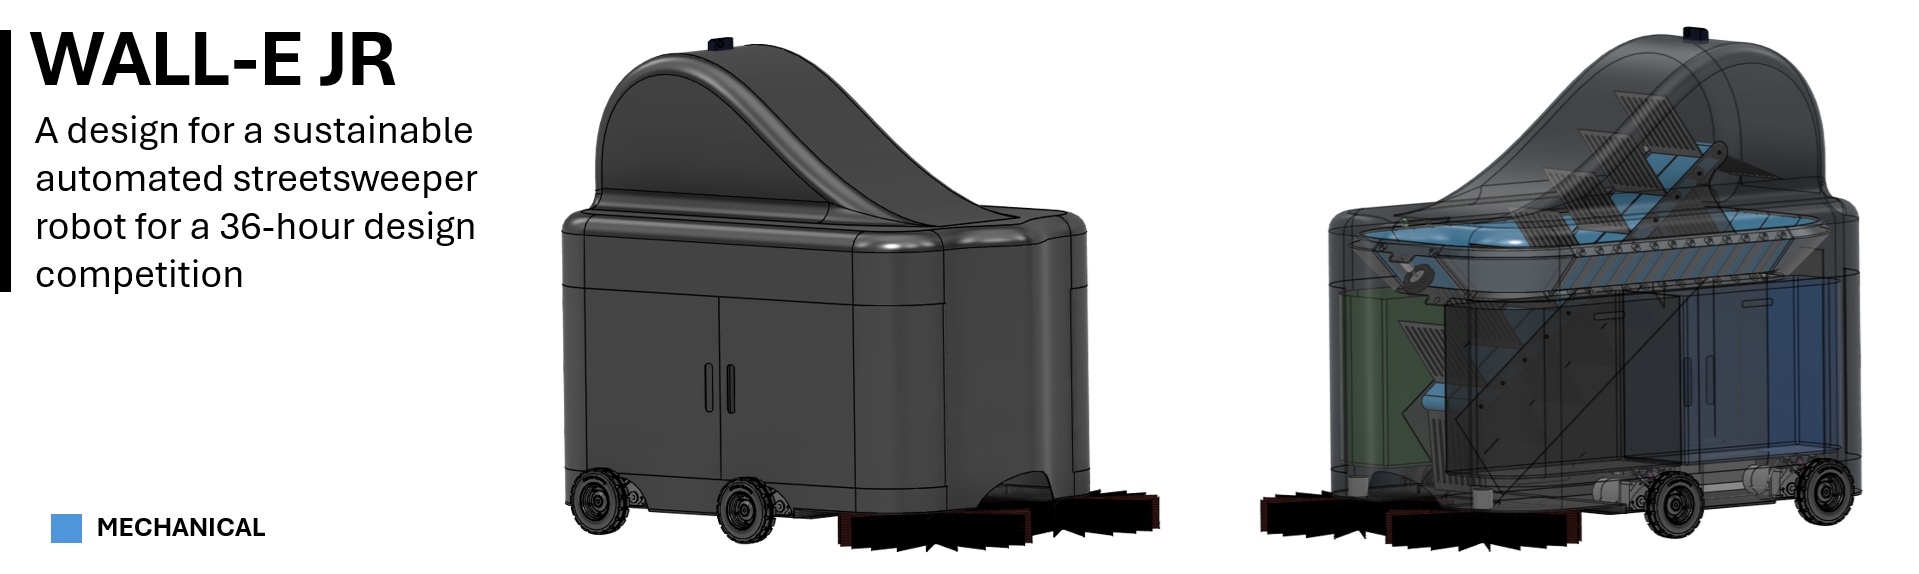
The Carleton University Design League hosted a designathon in which teams of 4 students compete to design and model an eco-friendly autonomous street sweeper. I participated with 3 friends and took on the role of team leader and waste collection system designer. Our goal was to create a robot that can collect and sort garbage while operating in the harsh winter conditions of Ontario. To fit the challenge requirements, we maximized our use of recyclable materials for this robot’s construction. We had 36 hours to complete our design and present our work to a panel of judges.
Design
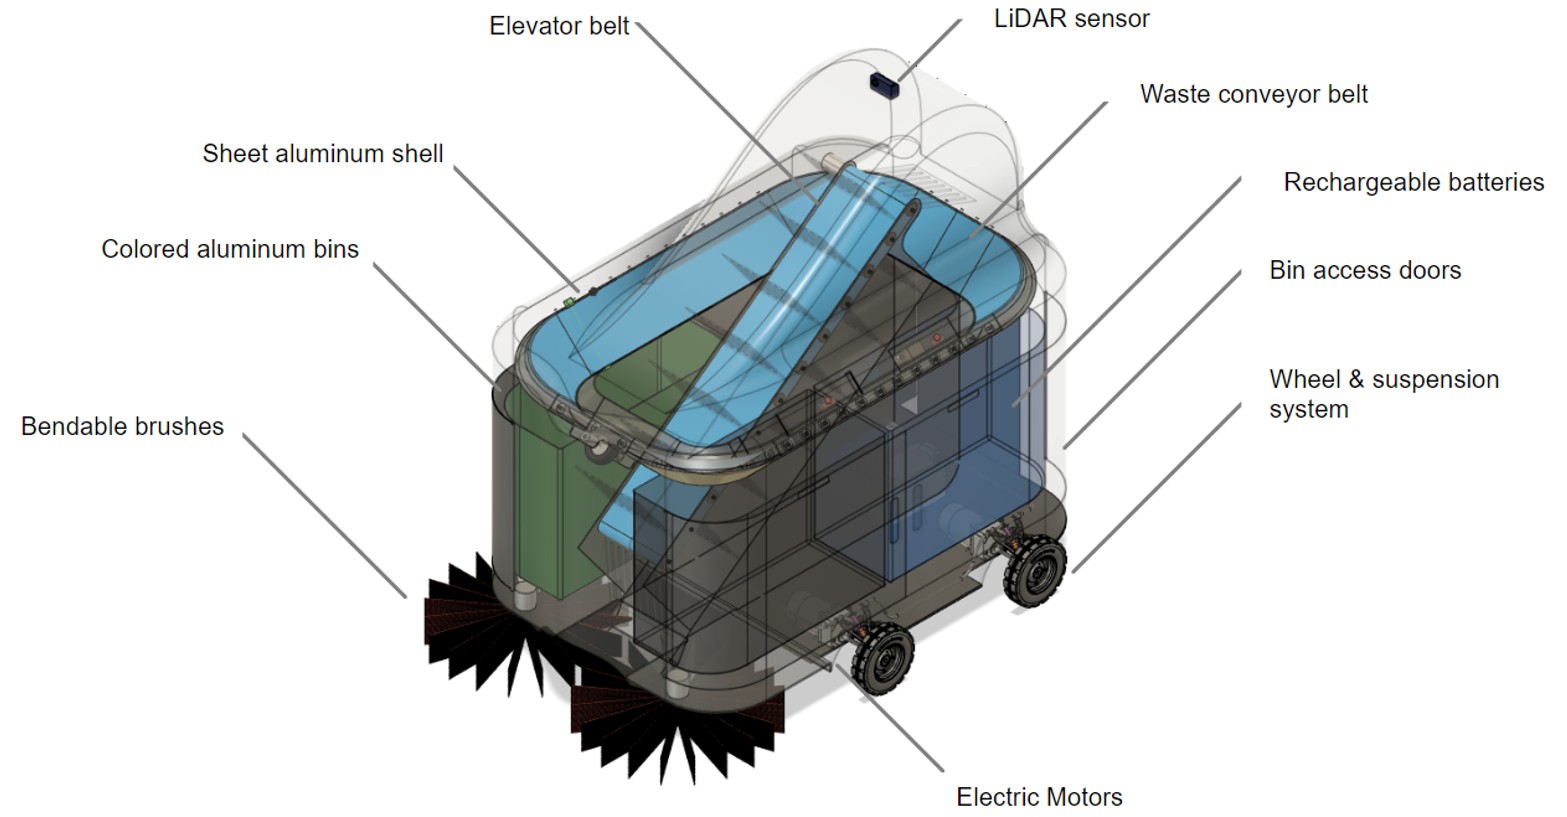 The Wall-E Jr robot is designed with principles of sustainable engineering in mind, which means it uses primarily recyclable materials (aluminum and rubber) and is simple to produce, assemble, and repair. It is designed to automatically drive around the streets of Ontario and collect and sort trash into four categories.
Streetsweeper Operation
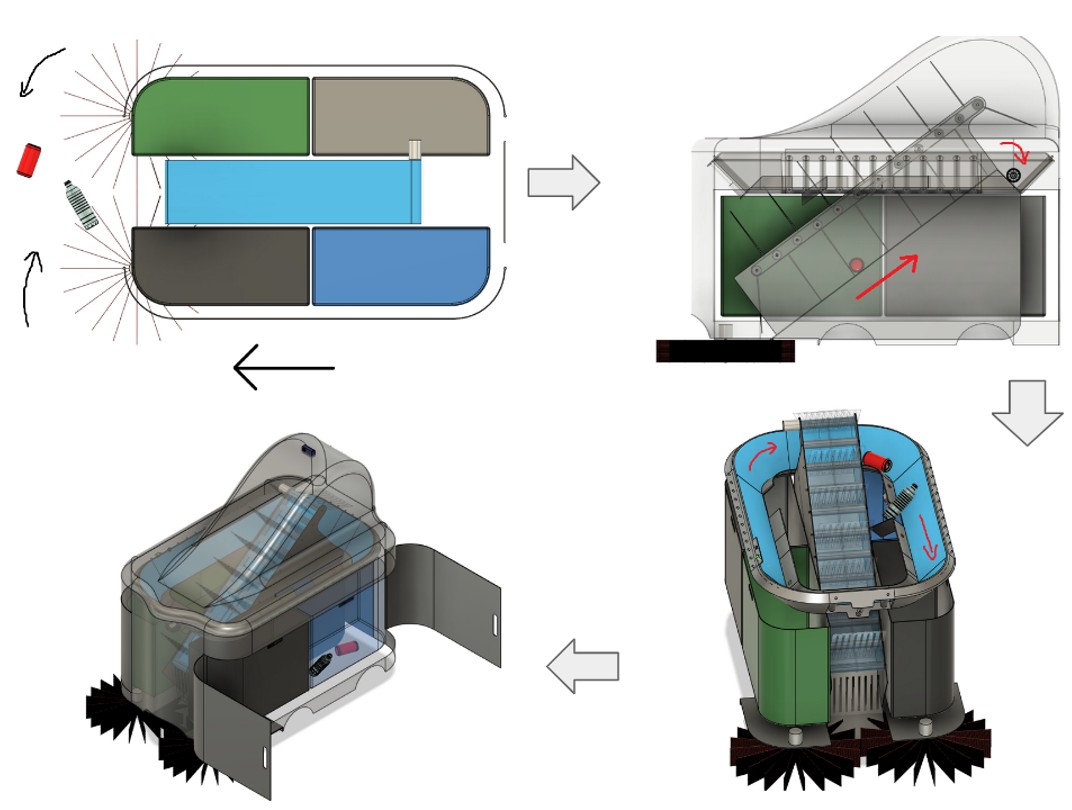
- Garbage is swept into the central chamber of the robot as it moves forward along a sidewalk
- The elevator brings the garbage up and drops it onto the sorting conveyer belt
- The garbage is then passed through 4 sensors that determines the category of the item (plastic, paper, compost, and non-recyclables) and drops them into the appropriate bins
- The garbage can be taken out once the robot returns to home station to recharge